Moving with position feedback
We programmed the robot to move side to side and keep track of its position. When it lost its place, we added a camera and a black-and-white reference strip so it could identify where it was and continue its route.
Working with a partner, I programmed a robot to navigate a timed competition map, calculate its shots, and operate its reloader autonomously.
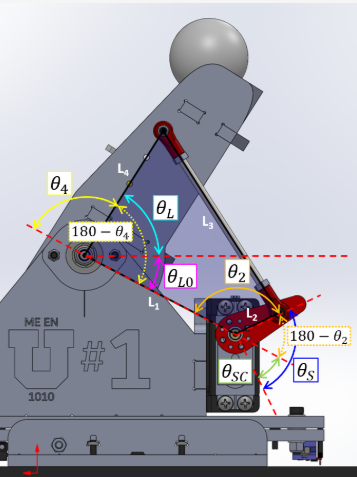
We assembled the robot from the materials provided, then focused on the software needed to navigate, aim, reload, and complete a timed run.
We programmed the robot to move side to side and keep track of its position. When it lost its place, we added a camera and a black-and-white reference strip so it could identify where it was and continue its route.
Our code calculated launch angle and firing force using target distance and air resistance. We also programmed the reloader’s dispensing sequence. Reload timing, launch angle, and firing force all required calibration and revised calculations during testing.
On competition day, we received a map of the locations the robot needed to hit. We wrote code to read those locations, plan a fast route between them, and start and stop the timer at the right points. Getting the map input and route selection to work reliably took additional calibration.
The robot completed its run and hit all of the mapped locations on competition day.